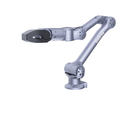
- Arm and Gripper in One Order The Z1 Pro arrives with the Z1 Gripper as its end effector, rather than as two separate purchases.
- At Least 3 kg Payload The Pro carries at least 3 kg at a 4.5 kg arm weight, more than the 2 kg of the Z1 Air.
- 740 mm Reach, ~0.1 mm Repeatability Six axes reach 740 mm with repeatability of about 0.1 mm, depending on test conditions.
- Position Plus Force Control Force feedback and collision detection support controlled contact with objects and surroundings.
- Built for Mobile Robots Running from 24 V with a 500 W maximum, the Z1 is designed to mount on mobile platforms as an onboard manipulator.
- Ethernet and Ubuntu The arm connects over Ethernet and is programmed from Ubuntu through Unitree's open programming interface.

Description
This package pairs the Unitree Z1 Pro, the higher-payload model of Unitree's 6-axis Z1 arm, with the Z1 Gripper as its end effector, so the arm and the gripper arrive as one order rather than two. Unitree designs the Z1 as an onboard manipulator for mobile robots, for work from e-commerce logistics to everyday handling, and it can also be used as a compact bench-top arm.
The Z1 Pro weighs 4.5 kg, reaches 740 mm and carries at least 3 kg, against the Z1 Air's 2 kg at 4.3 kg. Repeatability is about 0.1 mm. Every joint moves at up to 180°/s: J1 ±150°, J2 0–180°, J3 −165° to 0°, J4 ±80°, J5 ±85° and J6 ±160°. It runs from 24 V at more than 20 A with a 500 W maximum, connects over Ethernet and is programmed from Ubuntu, with position-plus-force control, force feedback and collision detection.
Unitree is open about the trade-off in that design. The joints use relatively low reduction ratios, so position-control stiffness is low, and without an optimised control mode the arm shows position error and shake in motion; repeatability also depends on the test conditions. For force-sensitive work and controlled contact that is the right compromise, and for rigid, high-precision positioning it is a point to plan the control software around.
The Z1 Gripper's stroke, grip force and weight, and the usable payload with the gripper fitted, are confirmed in writing with your quotation. If you already own a Z1 Pro, the gripper is also sold on its own, and for depth sensing at the jaws the Z1 grippers with Intel RealSense cameras are the alternatives.
Key Capabilities
- Arm and Gripper in One Order: The Z1 Pro arrives with the Z1 Gripper as its end effector, rather than as two separate purchases.
- At Least 3 kg Payload: The Pro carries at least 3 kg at a 4.5 kg arm weight, more than the 2 kg of the Z1 Air.
- 740 mm Reach, ~0.1 mm Repeatability: Six axes reach 740 mm with repeatability of about 0.1 mm, depending on test conditions.
- Position Plus Force Control: Force feedback and collision detection support controlled contact with objects and surroundings.
- Built for Mobile Robots: Running from 24 V with a 500 W maximum, the Z1 is designed to mount on mobile platforms as an onboard manipulator.
- Ethernet and Ubuntu: The arm connects over Ethernet and is programmed from Ubuntu through Unitree's open programming interface.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Unitree Robotics |
|---|---|
| Model | Z1 Pro + Z1 Gripper |
| Product Type | 6-axis robot arm with gripper |
| Degrees of Freedom | 6 axes |
| Arm Weight | 4.5 kg |
| Payload | ≥3 kg (arm rating) |
| Usable Payload with Gripper Fitted | Confirm at quote |
| Reach | 740 mm |
| Repeatability | ~0.1 mm (depends on test conditions) |
| Joint Range J1 | ±150° |
| Joint Range J2 | 0–180° |
| Joint Range J3 | −165° to 0° |
| Joint Range J4 | ±80° |
| Joint Range J5 | ±85° |
| Joint Range J6 | ±160° |
| Max Joint Speed | 180°/s (all joints) |
| Power Supply | 24 V, >20 A |
| Maximum Power | 500 W |
| Interface | Ethernet |
| User Operating System | Ubuntu |
| Control Interface | Position + force control |
| Force Feedback and Collision Detection | Yes |
| End Effector | Unitree Z1 Gripper |
| Gripper Stroke, Grip Force and Weight | Confirm at quote |
Industries
Frequently Asked Questions
Yes. It is the Z1 Pro arm and the Z1 Gripper together, so the arm arrives with its end effector instead of as two separate purchases.
The Pro carries at least 3 kg against the Air's 2 kg and weighs 4.5 kg against 4.3 kg. Reach, repeatability, joint ranges, power supply and Ethernet interface are the same on both.
They are confirmed with your quotation, together with the gripper's weight and the usable payload with the gripper fitted.
The Z1's joints use relatively low reduction ratios, which suits force control but lowers position-control stiffness. Without an optimised control mode the arm can show position error and shake, so plan the control software for precise positioning tasks.
The Unitree Z1 Pro Robot Arm with Z1 Gripper is priced at 356 936,03 Kč in your market.
Yes, the Z1 is designed as an onboard manipulator for mobile robots, running from 24 V. The mounting interface to your platform is confirmed with your quotation.
Recently Viewed
You haven't viewed any products yet.