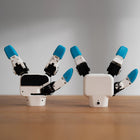
- Left-Hand Version, One Unit Part number 4010700101 equips a left-side arm or pairs with the right-hand version.
- Six Servo-Driven Joints Three fingers move through six joints, each on its own digital servo motor.
- Ten Torque Levels Grip force is set in ten steps up to the 500 g rated load, across a 0–130 mm stroke.
- Made for Lab Objects Tools, food, fruit and laboratory objects are among the items the hand is designed to grasp.
- Open Protocols and ROS Serial-port and motor-control protocols are open, with Python, ROS1, ROS2 and RViz support.
- 100 Hz Grasp Status High-frequency communication over RS-485 reports grasping status in real time.


Description
The myGripper H100 Left Hand (part number 4010700101) is the left-handed version of Elephant Robotics' three-finger dexterous hand, supplied as one unit. It is made for the myCobot Pro 630 and the Mercury series, and it is the hand to choose when the arm you are equipping works as a left hand, such as the left arm of a two-armed setup.
Bought alone, it covers one arm. Together with the right-hand version (part number 4010700100), or as the matched Left + Right pair that has its own listing, it equips both sides. Apart from handedness, the left and right hands share one specification.
The hand is built for research, teaching and laboratory demonstrations. Three fingers move through six joints, each on its own digital servo with current, position and speed control. A program can therefore choose an output torque from ten levels, up to the 500 g rated load, and an absolute finger position, which suits handling tools, food, fruit and laboratory objects as well as hand-like gestures. The opening stroke runs 0–130 mm, and the joints move at 60° per second.
On the electrical side it takes 24 V at 2 A through an M8 aviation connector and communicates over RS-485 using MODBUS (Hex, 8N1), with grasp status reported through 100 Hz high-frequency communication. An ESP32 dual-core chip controls the hand. Python, ROS1, ROS2 and RViz simulation are supported, and the serial and motor-control protocols are open. It weighs 780 g and is rated for 1,000,000 cycles or more.
Key Capabilities
- Left-Hand Version, One Unit: Part number 4010700101 equips a left-side arm or pairs with the right-hand version.
- Six Servo-Driven Joints: Three fingers move through six joints, each on its own digital servo motor.
- Ten Torque Levels: Grip force is set in ten steps up to the 500 g rated load, across a 0–130 mm stroke.
- Made for Lab Objects: Tools, food, fruit and laboratory objects are among the items the hand is designed to grasp.
- Open Protocols and ROS: Serial-port and motor-control protocols are open, with Python, ROS1, ROS2 and RViz support.
- 100 Hz Grasp Status: High-frequency communication over RS-485 reports grasping status in real time.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Elephant Robotics |
|---|---|
| Model | myGripper H100, left hand |
| Part Number | 4010700101 |
| Product Type | Three-finger dexterous robotic hand, single unit |
| Hand | Left |
| Fingers | 3 |
| Movable Joints | 6 |
| Motors | 6 digital servo motors supporting current, position and speed control |
| Payload | 500 g |
| Torque Adjustment | 10 levels |
| Stroke (diameter) | 0–130 mm |
| Motion Speed | 60° per second per joint |
| Weight | 780 g |
| Lifespan | 1,000,000 cycles or more |
| Electrical Interface | M8 aviation connector |
| Power | 24 V, 2 A |
| Communication Interface | RS-485 |
| Communication Rate | Rated above 50 Hz; 100 Hz high-frequency communication for grasp-status monitoring |
| Protocol | MODBUS; Hex data format, 8N1 |
| Main Control Chip | ESP32, 240 MHz dual-core, 600 DMIPS, 520 KB SRAM, Wi-Fi, dual-mode Bluetooth |
| Programming | Python; ROS1, ROS2 and RViz simulation; open serial-port and motor-control protocols |
| Compatible Models | myCobot Pro 630, Mercury series |
| What's in the Box | Three-finger dexterous hand (left); dual-head 8-pin aviation connector cable; extension cable; USB-to-485 module; 8-pin aviation connector with 2 m extension cable; USB data cable |
Industries
Frequently Asked Questions
The left hand, part number 4010700101. The right hand (4010700100) has its own listing, and the matched Left + Right pair is sold as a separate product.
No. Payload, weight, stroke, joints, power and communication are identical for both; only the handedness differs.
The myCobot Pro 630 and the Mercury series, according to Elephant Robotics. Confirm your arm model with us before ordering.
Up to 500 g, with ten torque levels for setting grip force across a 0–130 mm stroke. It is designed for tools, food, fruit and laboratory objects.
The left hand, a dual-head 8-pin aviation connector cable, an extension cable, a USB-to-485 module, an 8-pin aviation connector with a 2 m extension cable and a USB data cable.
The Elephant Robotics myGripper H100 Left Hand is priced at 19 800 Kč in your market.
Recently Viewed
You haven't viewed any products yet.